Projects · Part I
Mono-Hydra
Where it started. The first real-time 3D scene graph built from a monocular camera and an IMU.
01 — The system
What it does
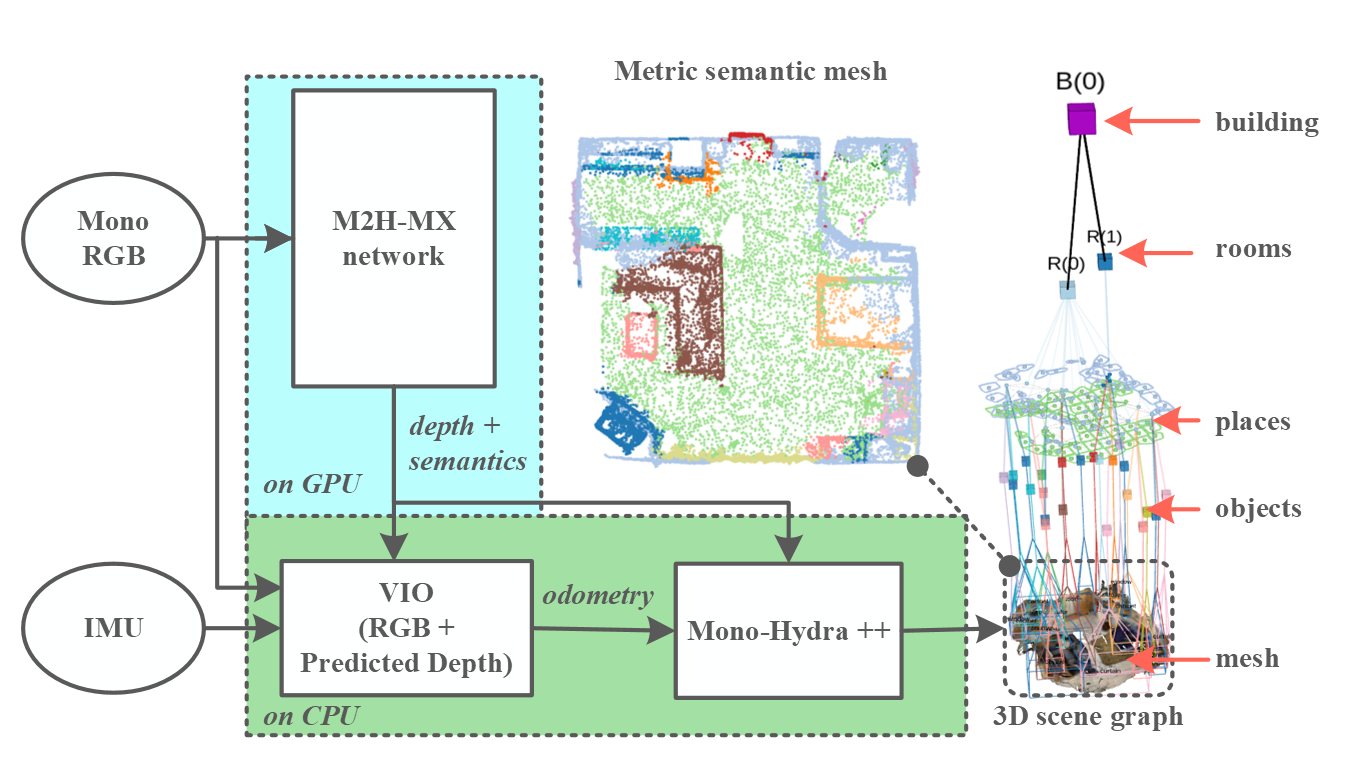
Learned depth and learned semantics run as separate networks, feeding a robocentric square-root VIO and the Hydra scene graph layers: mesh, objects, places, rooms, buildings.
Engineering ownership
My contribution
- Developed and integrated monocular learned perception, visual-inertial odometry and hierarchical scene graph construction.
System sketch
From camera measurements to a layered map
- 01MeasureMonocular camera + IMU
- 02PredictSeparate depth and semantic networks
- 03Estimate & reconstructRobocentric VIO + semantic mesh
- 04StructureObjects, places, rooms, building
02 — Evidence
Measured
Key numbers
- 0.19 m and 0.21 m ITC mean error
- 15 fps at 848x480
- RTX 3080 8GB laptop
Every figure here appears in the thesis results registry with its source location. Conditions are stated with the number.