Papers & technical evidence
Publications.
Perception, SLAM & exploration.
Papers are indexed under U.V.B.L. Udugama, and the earlier ones under B. Udugama.
Research papers
-
2026 / Under review at ISPRS Journal of Photogrammetry and Remote Sensing
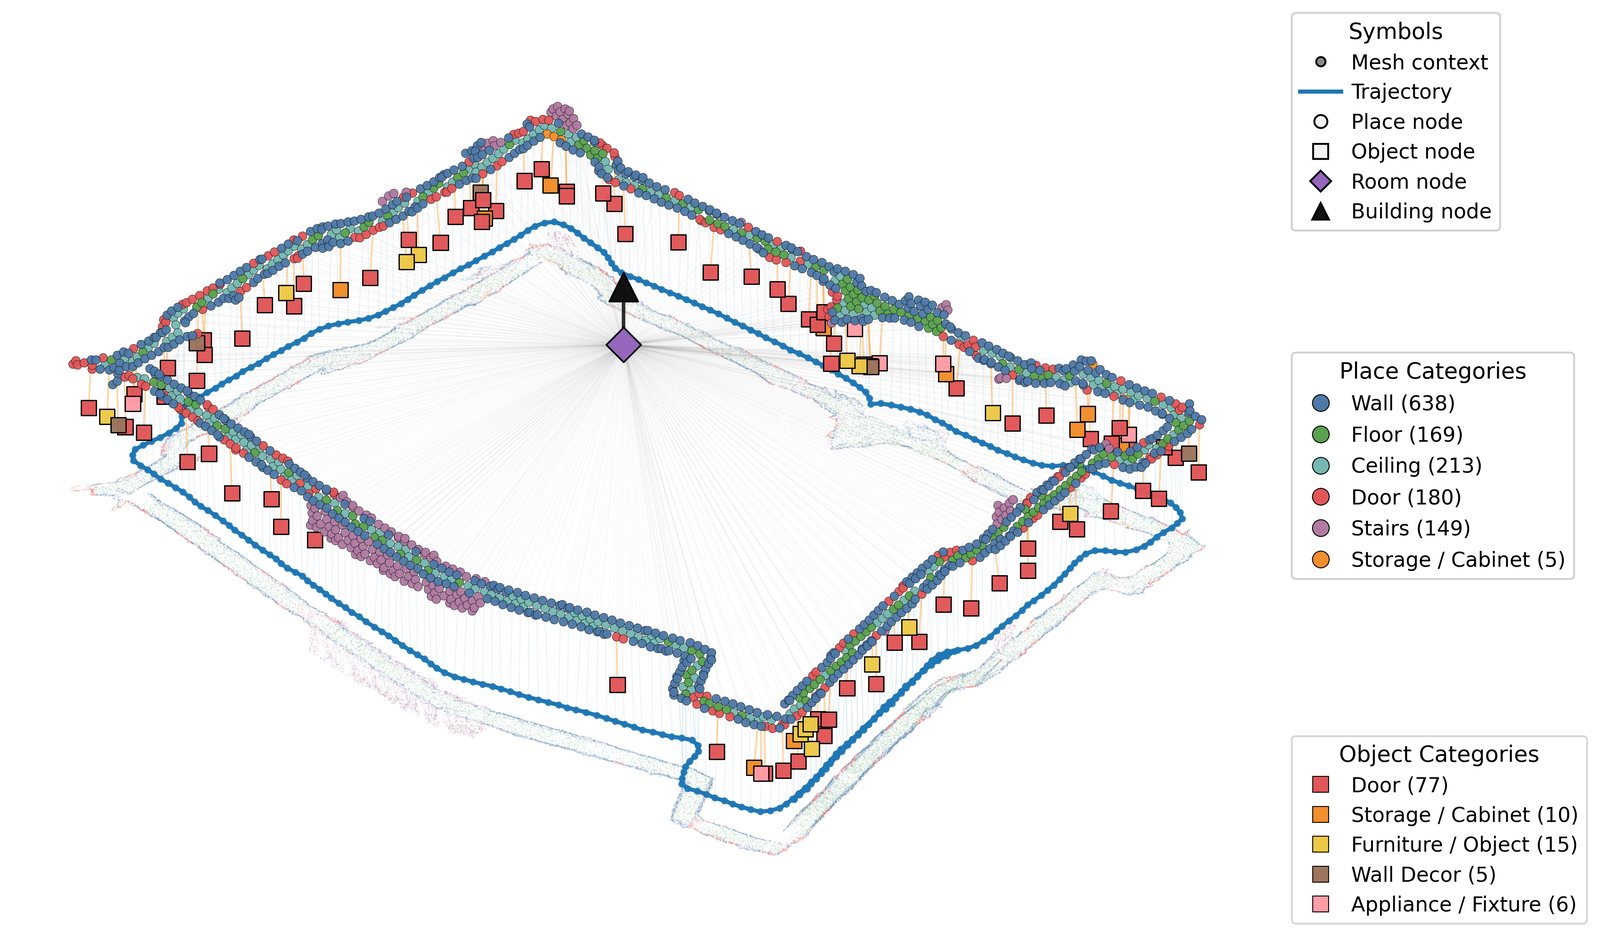
Mono-Hydra++: Real-Time Monocular Scene Graph Construction with Multi-Task Learning for 3D Indoor Mapping
ISPRS Journal of Photogrammetry and Remote Sensing Under review
A single camera and an IMU build a hierarchical metric-semantic 3D scene graph of an indoor building in real time, and the map is accurate to 0.08 m.
-
2026 / Accepted, ICRA 2026 SRRA Workshop
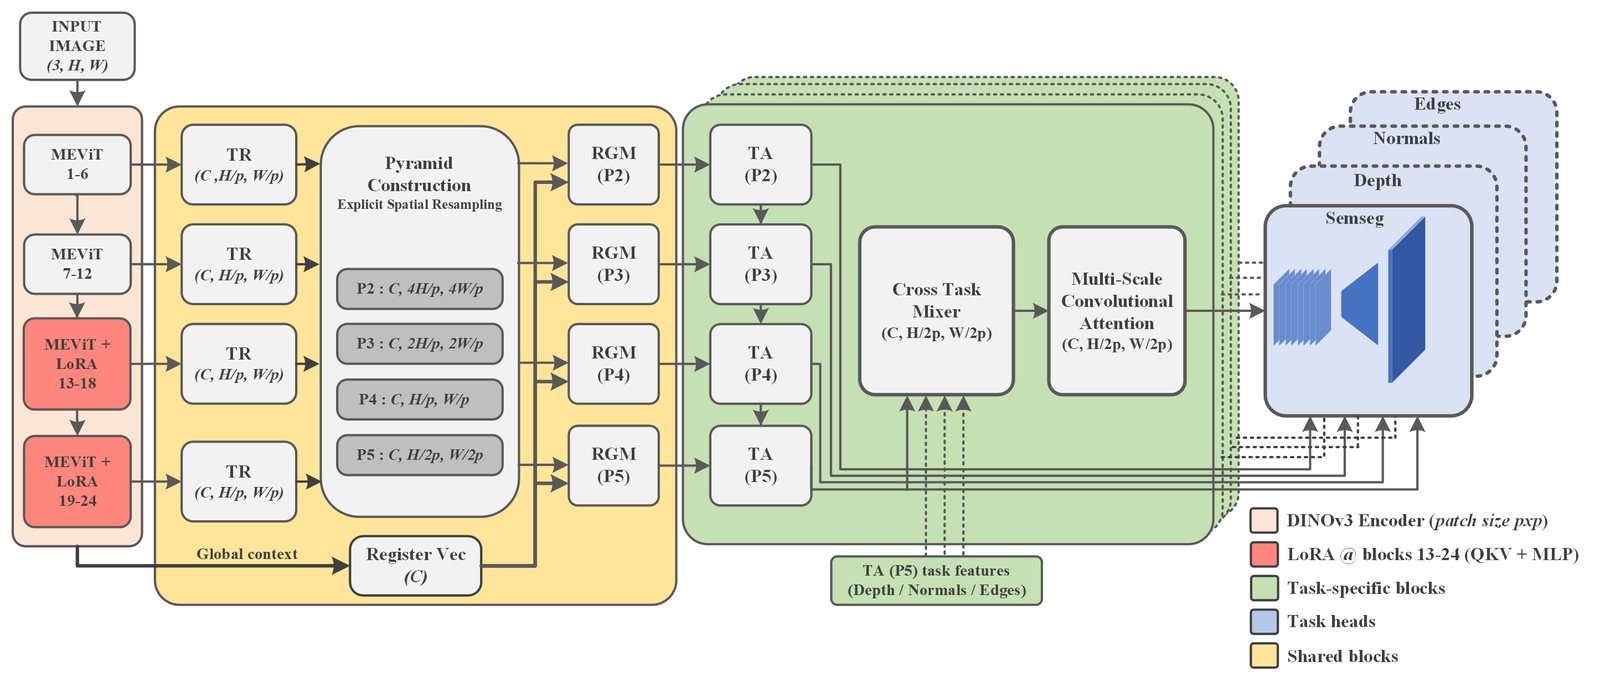
M2H-MX: Multi-Task Semantic and Geometric Perception for Real-Time Monocular 3D Scene Graph Construction
IEEE International Conference on Robotics and Automation (ICRA) 2026, SRRA Workshop, Vienna
Better per-frame depth and semantics measurably improve the map and the trajectory, not just the benchmark score.
-
2025 / Published, IEEE/RSJ IROS 2025
M2H: Multi-Task Learning with Efficient Window-Based Cross-Task Attention for Monocular Spatial Perception
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025
Four dense prediction tasks share one small model and make each other better, fast enough to sit inside a mapping loop.
-
2023 / Published, ISPRS Annals 2023
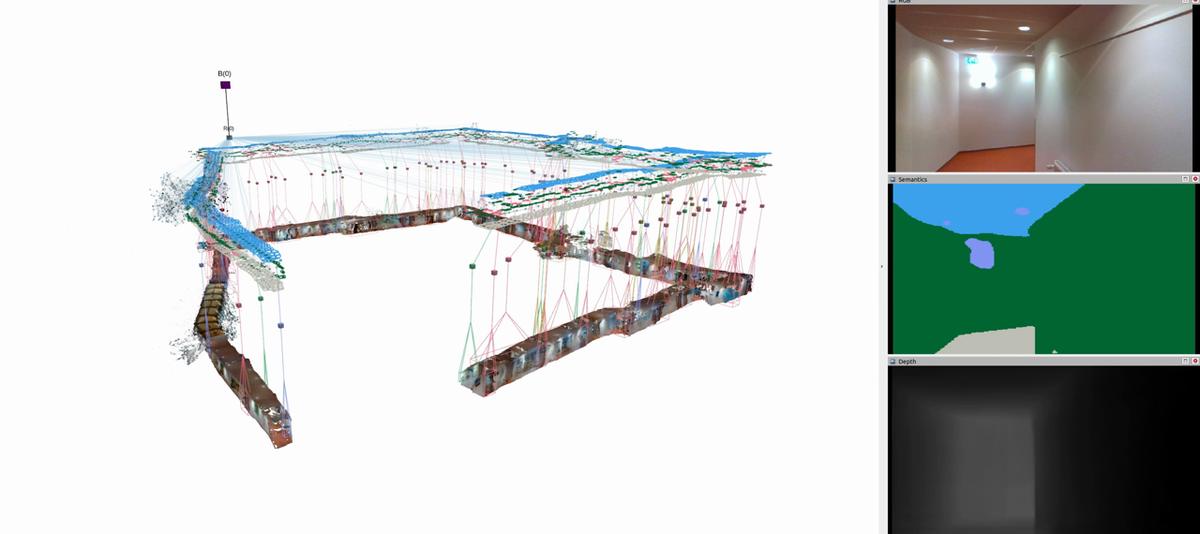
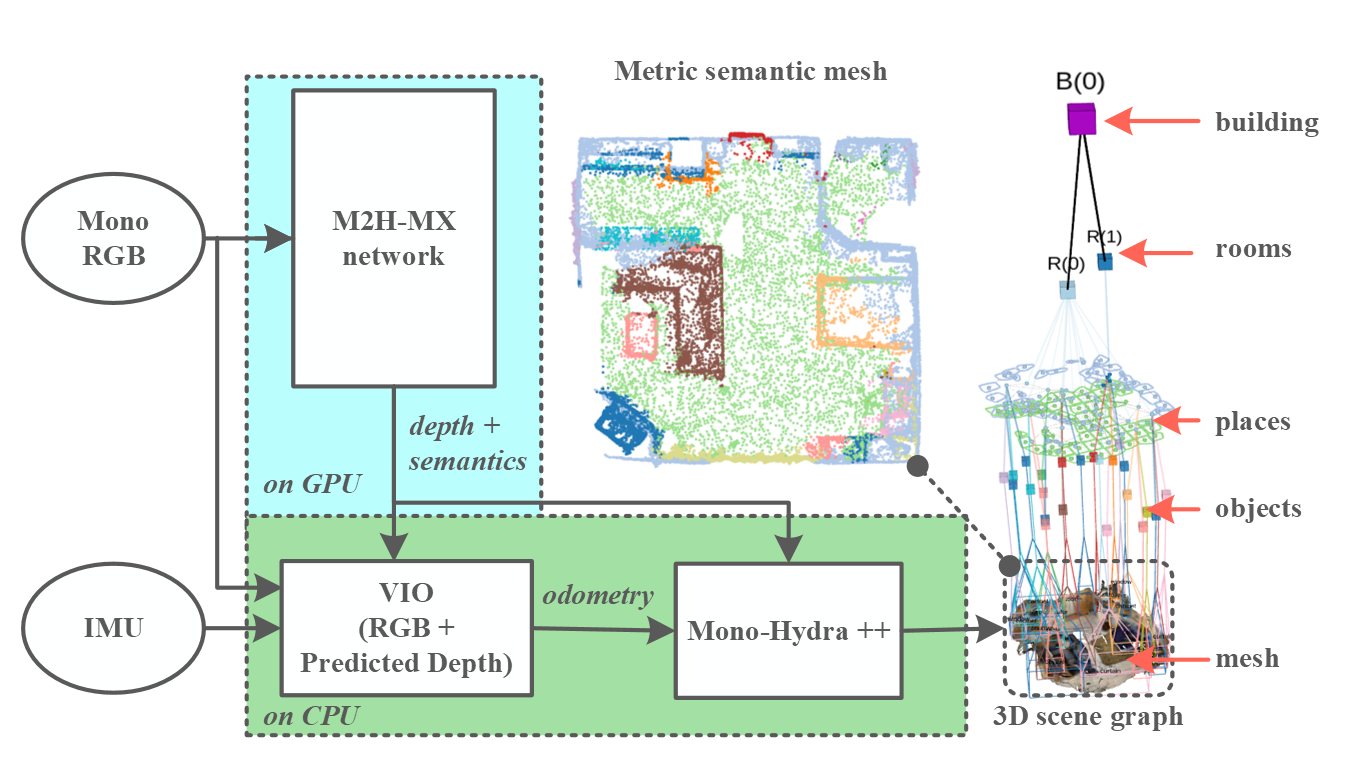
Mono-Hydra: Real-Time 3D Scene Graph Construction from Monocular Camera Input with IMU
ISPRS Annals of the Photogrammetry, Remote Sensing and Spatial Information Sciences, volume 1, pages 439 to 445
A monocular camera and an IMU can build a layered 3D scene graph while the robot is still moving, without a depth sensor or LiDAR.
Review preprints
Single-author literature reviews written during the MSc at Middlesex University Dubai, posted to arXiv later. Not peer reviewed.
-
Evolution of SLAM: Toward the Robust-Perception of Autonomy
arXiv preprint, written 2021, posted February 2023
Preprint, not peer reviewed
A survey of how SLAM developed from filtering approaches through graph optimisation towards learned components.
-
Review of Deep Reinforcement Learning for Autonomous Driving
arXiv preprint, written 2021, posted February 2023
Preprint, not peer reviewed
A survey of deep reinforcement learning applied to autonomous driving, and why results in games transfer badly to the road.
-
Review on Efficient Strategies for Coordinated Motion and Tracking in Swarm Robotics
arXiv preprint, written 2021, posted February 2023
Preprint, not peer reviewed
A survey of coordinated motion and tracking strategies in swarm robotics.
Earlier work
Undergraduate research at the University of Peradeniya, and the MSc thesis.
-
Autonomous exploration planning strategy for a reconnaissance agent
2017 IEEE International Conference on Industrial and Information Systems (ICIIS), pages 1 to 6, 2017
SLAM developer, one of 3 students on the project
Autonomous exploration planning for a robot mapping an unknown space. The same question the current work asks, 10 years earlier.
-
Object Dimension Extraction for Environment Mapping with Low Cost Cameras Fused with Laser Ranging
24th Annual Technical Conference of the IET Sri Lanka Network, 2017
Best Technical Paper, IET Sri Lanka, 2017
-
Laser Ranging Based Intelligent System for Unknown Environment Mapping
Annual Sessions 2017, The Institution of Engineers Sri Lanka, 2017
Best Undergraduate Project, Institution of Engineers Sri Lanka, 2017
-
Heterogeneous swarm robot system with distributed data processing at the edge for collective transportation
MSc thesis, Robotics Engineering, Middlesex University Dubai, 2021, Distinction
All BibTeX entries · Google Scholar for citation counts.